A robot entering a damaged building or another hazardous place must do more than repeat a motion learned on a clean laboratory floor. It has to remain useful when the ground changes or an obstacle appears. Researchers can investigate that adaptability before a complete operational mission is available. The resulting demonstrations need a clear boundary between a learned movement skill, human guidance and the broader task the robot may eventually support.
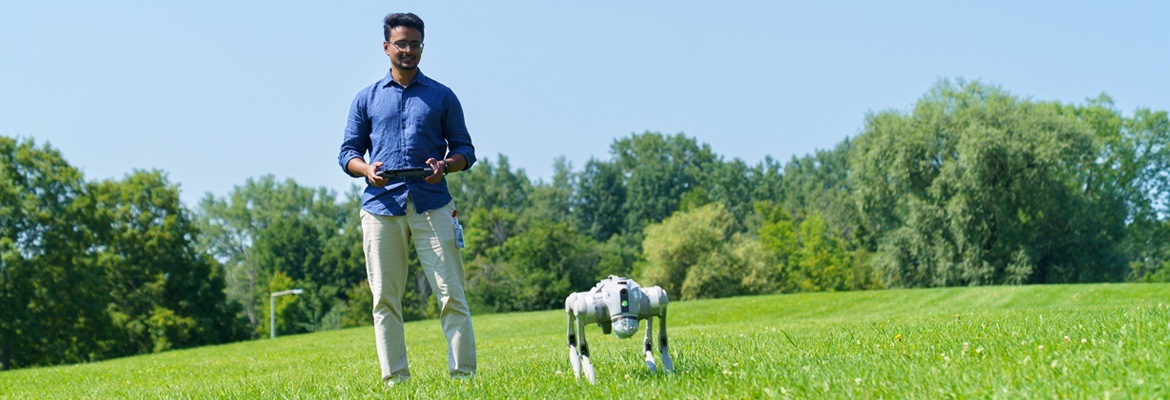
National Research Council Canada’s October 28 account describes Rocky, a knee-high quadruped used to study adaptable autonomy. Researchers train it with reinforcement learning in simulation before physical trials on different surfaces. The accompanying transcripts explicitly describe current remote guidance and the goal of greater autonomy. Firefighting, disaster recovery and other hazardous work are potential applications, rather than services the source establishes Rocky is already delivering. Read the primary source account.
A learned skill is part of a larger system
The account identifies inertial sensing, a camera, LiDAR and foot-force sensors. Those inputs can help a robot estimate motion and contact while responding to its surroundings. Having the sensors does not, by itself, establish that the machine understands a disaster scene or can complete an unsupervised search. The relevant research result concerns the connection between observations and movement under the selected training and test conditions.
Reinforcement learning changes behavior through feedback on attempted actions. The feedback defines which outcomes are rewarded, so it becomes part of the task specification. A policy that learns to reach the top of a slope has addressed a more bounded problem than one asked to decide where to go and why. Preserving that distinction makes the locomotion work informative without inflating it into a claim of general operational reasoning.
Simulation provides practice and introduces assumptions
A virtual environment can supply many controlled attempts before physical testing. Its usefulness depends on how well the represented conditions capture what matters on the real machine. A successful simulated run is evidence about that environment; physical trials test a further connection. Both belong in the record, rather than allowing one to replace the other whenever it produces the more impressive demonstration.
NRC’s account includes work in a simulated lunar-terrain facility and discusses possible exploration uses. The setting should not be mistaken for a mission on the Moon or qualification for one. It offers a controlled way to examine selected terrain problems. The same caution applies to disaster-response ambitions: a terrain test can support movement research while leaving sensing, communications and the actual responder workflow for additional development.
Interventions make the evidence interpretable
The published transcripts include remote control and a sequence involving falls before a successful attempt. Those details are useful because they keep the demonstration from appearing more independent or uniformly successful than the account supports. Recording intervention does not invalidate a research trial. It identifies the part of the operating process still supplied by a person and helps define what improvement would mean.
A fuller evaluation could report attempted traversals, successful completions and the conditions requiring assistance. That would allow another team to distinguish repeatable adaptation from a selected success. It could also show whether a change helps across surfaces or only under one familiar condition. The public story does not supply a complete comparative benchmark, so claims about superiority over other robots would go beyond its evidence.
The distinction is particularly important for a responder who might rely on the robot’s position or view. A machine that crosses a surface successfully can still need help deciding which observation matters to the mission. Connecting the movement policy to that decision pathway is a separate development objective. NRC’s account leaves room for that work rather than presenting future hazardous-environment use as already validated. Preserving the boundary helps readers assess progress against the research objective without asking a selected terrain demonstration to prove a complete service.
For emergency and industrial users, the immediate contribution is research into a capability that could eventually reduce exposure to difficult terrain. It is not a new procurement-ready rescue system. The longer-term value depends on integrating adaptable movement with a defined mission and dependable human oversight. The next persuasive evidence is a reproducible account of physical trials, including recoveries and remaining guidance. That would show which part of the hazardous-work problem the research has actually reduced, while keeping future applications conditional.
Source organizations: National Research Council Canada.
References
Questions, news tips or corrections? Contact [email protected].